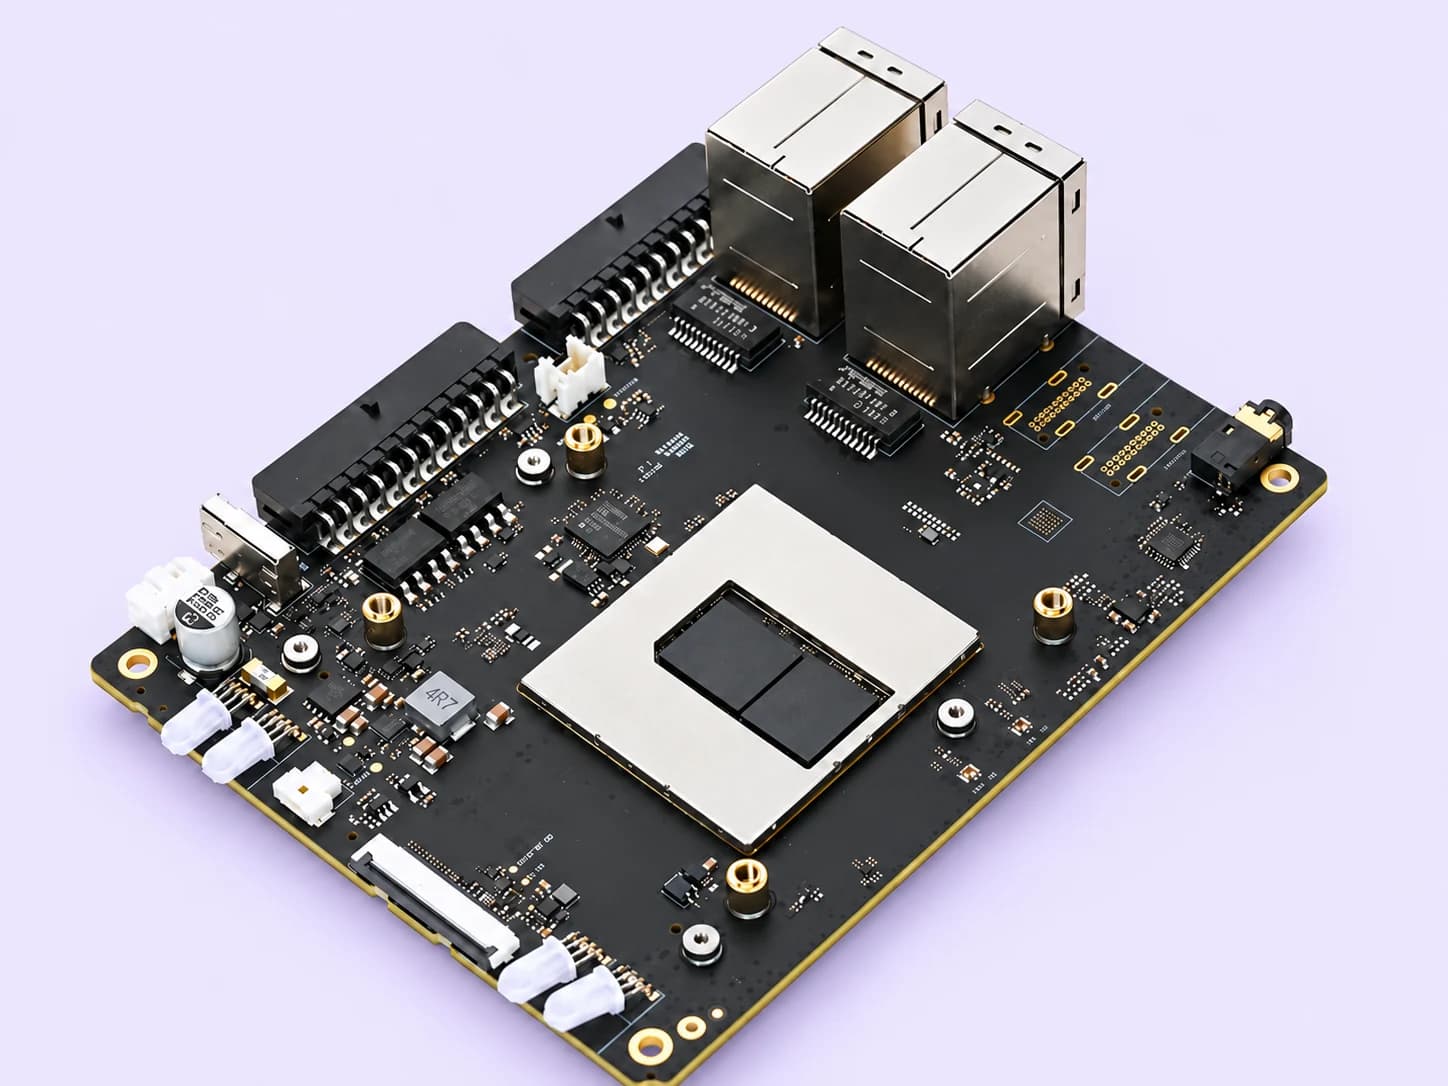
Empowering the Next Generation of Embodied Intelligence
Duolix is building an open hardware and software ecosystem for Physical AI, connecting Android interaction, Linux robotics and edge AI development.
Read the visionClose the introduction
Democratizing Physical AI
Our vision is to make robotic intelligence more accessible by bringing neural perception, higher-level planning and dedicated motor control into a modular developer ecosystem.
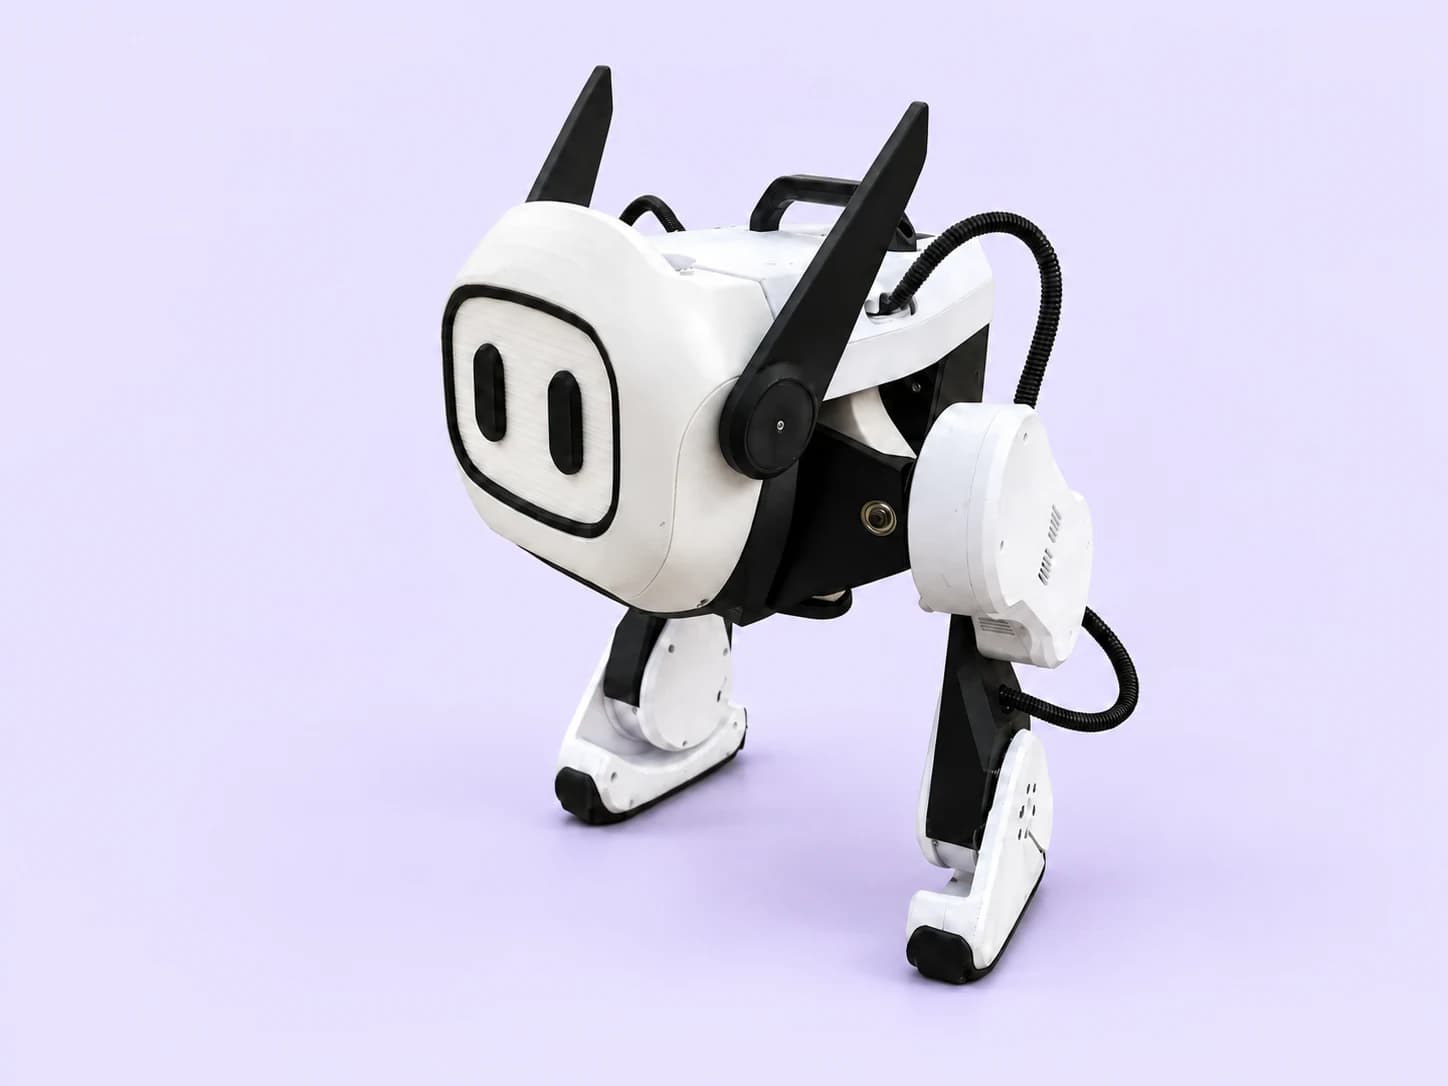
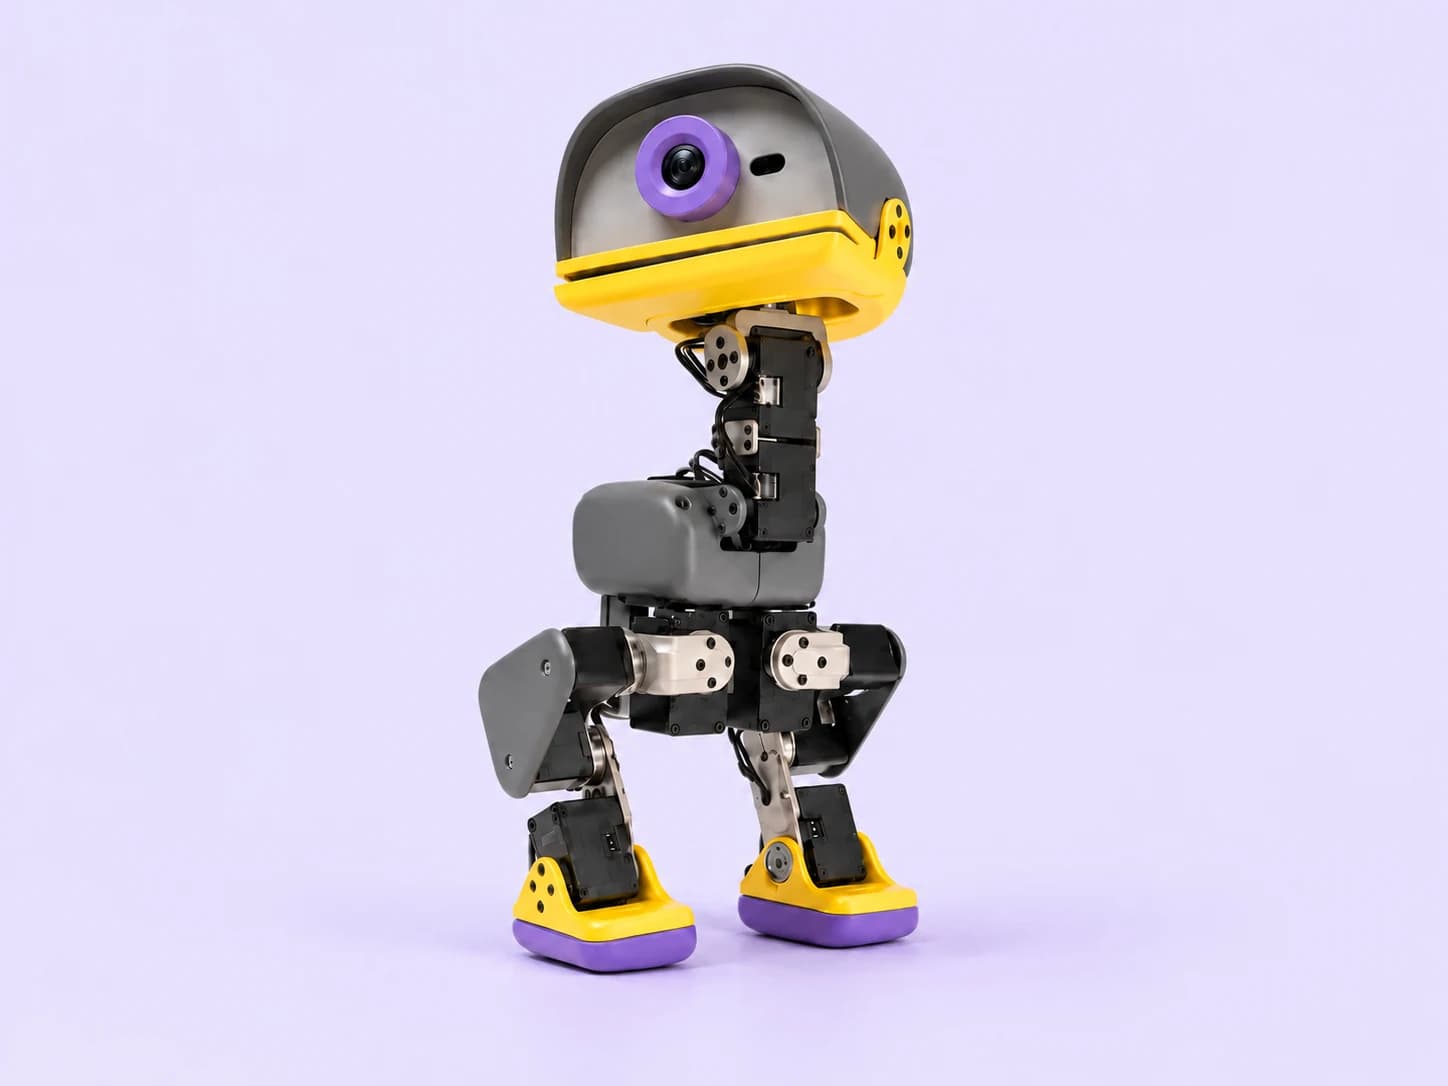
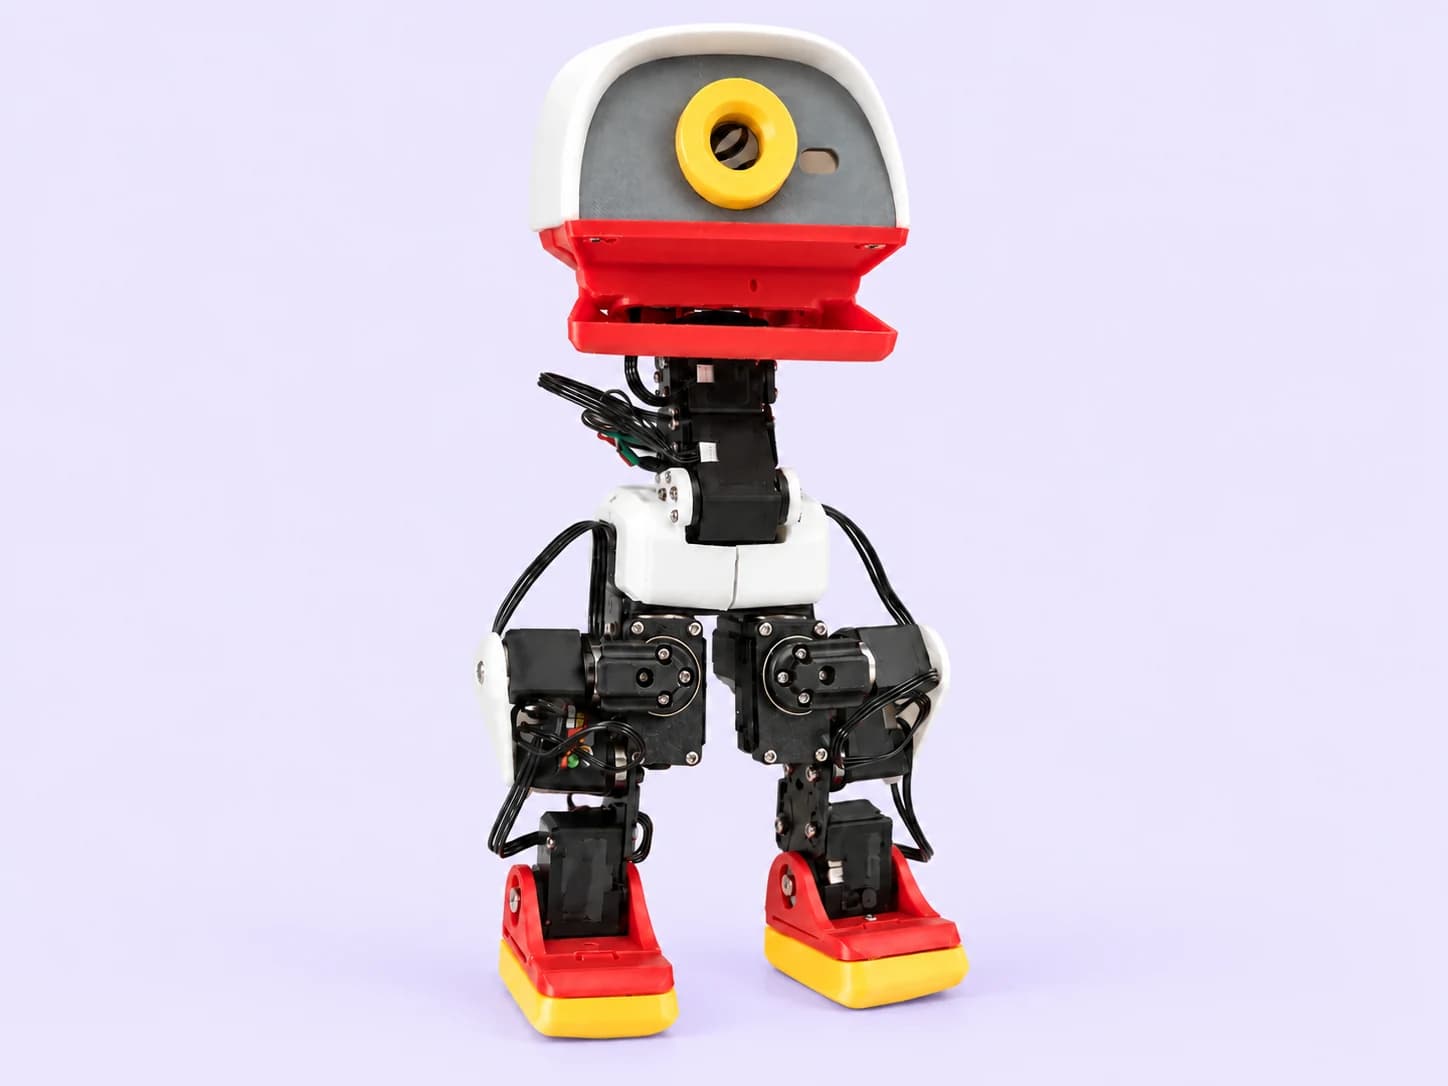
Explore community robot projects, published build resources, developer guides and reference kits. Each project links to its original authors and available source materials.
Open project resources
Find source materials and licenses at the project level, with room for community collaboration and customization.
Connected edge development
Bring application, inference and robot-control workflows closer together, with board support documented as it is validated.
Modular prototyping
Start with reference projects and component lists, then adapt the build to your research or engineering goals.
Core Platform Pillars
High-Performance Edge Compute
Develop perception and local inference workflows for supported edge hardware. Match model formats and accelerator backends to the selected device and software image.
Our architecture direction connects higher-level robotics planning with dedicated motor-control firmware. Timing, actuator interfaces and stop behavior need validation for each physical build.
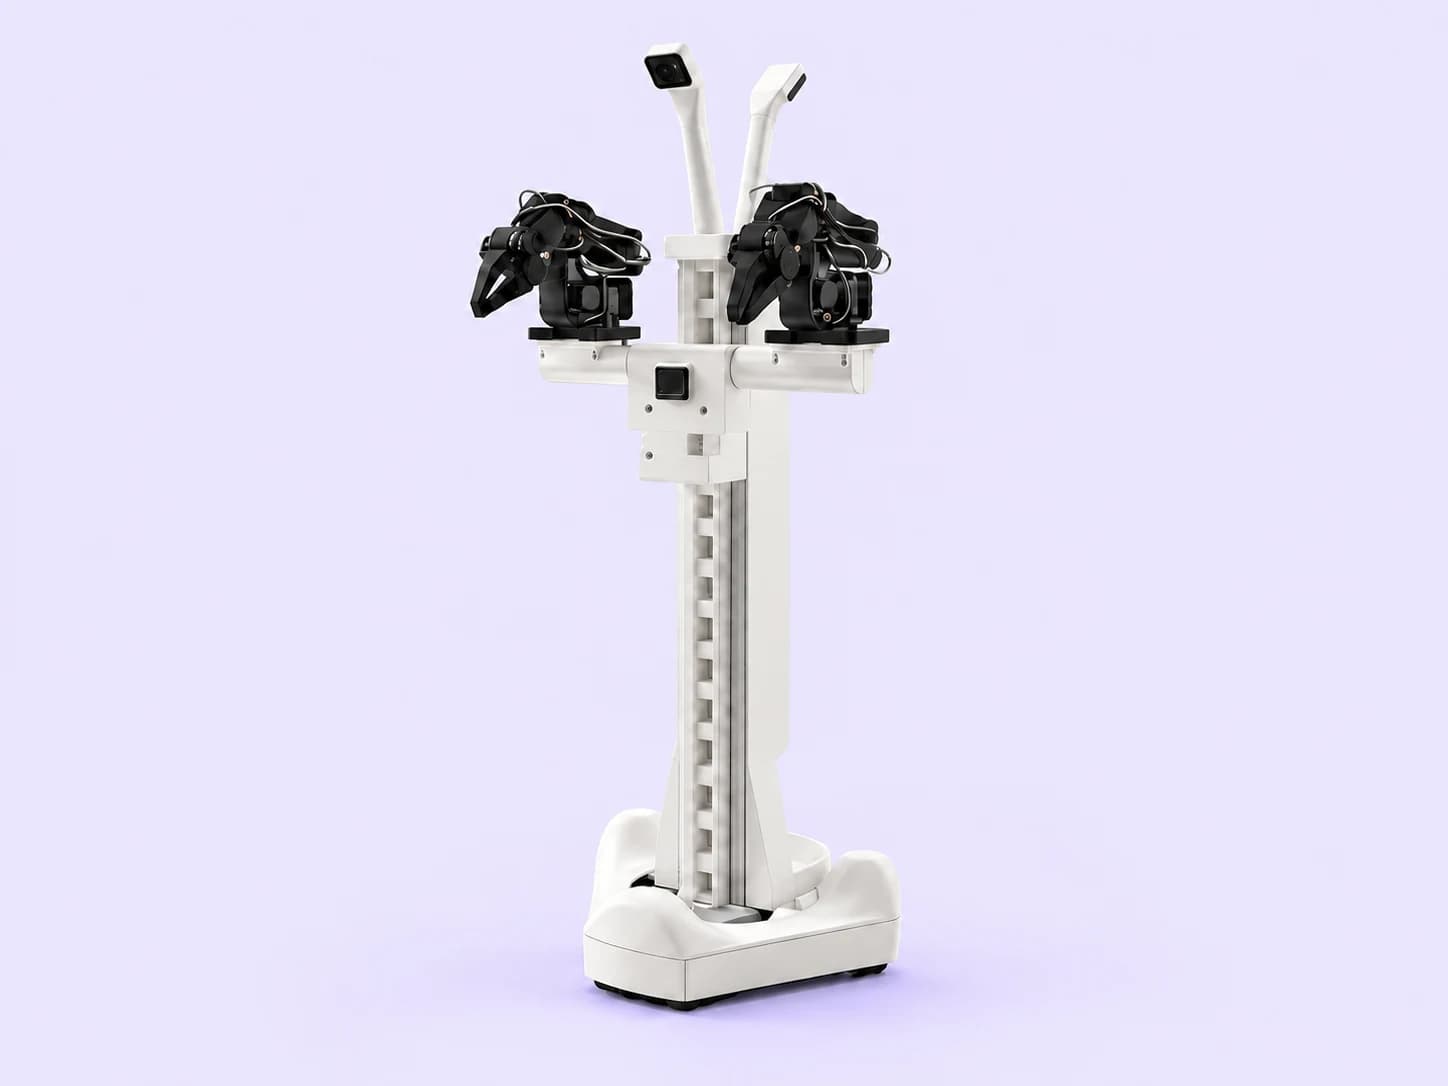
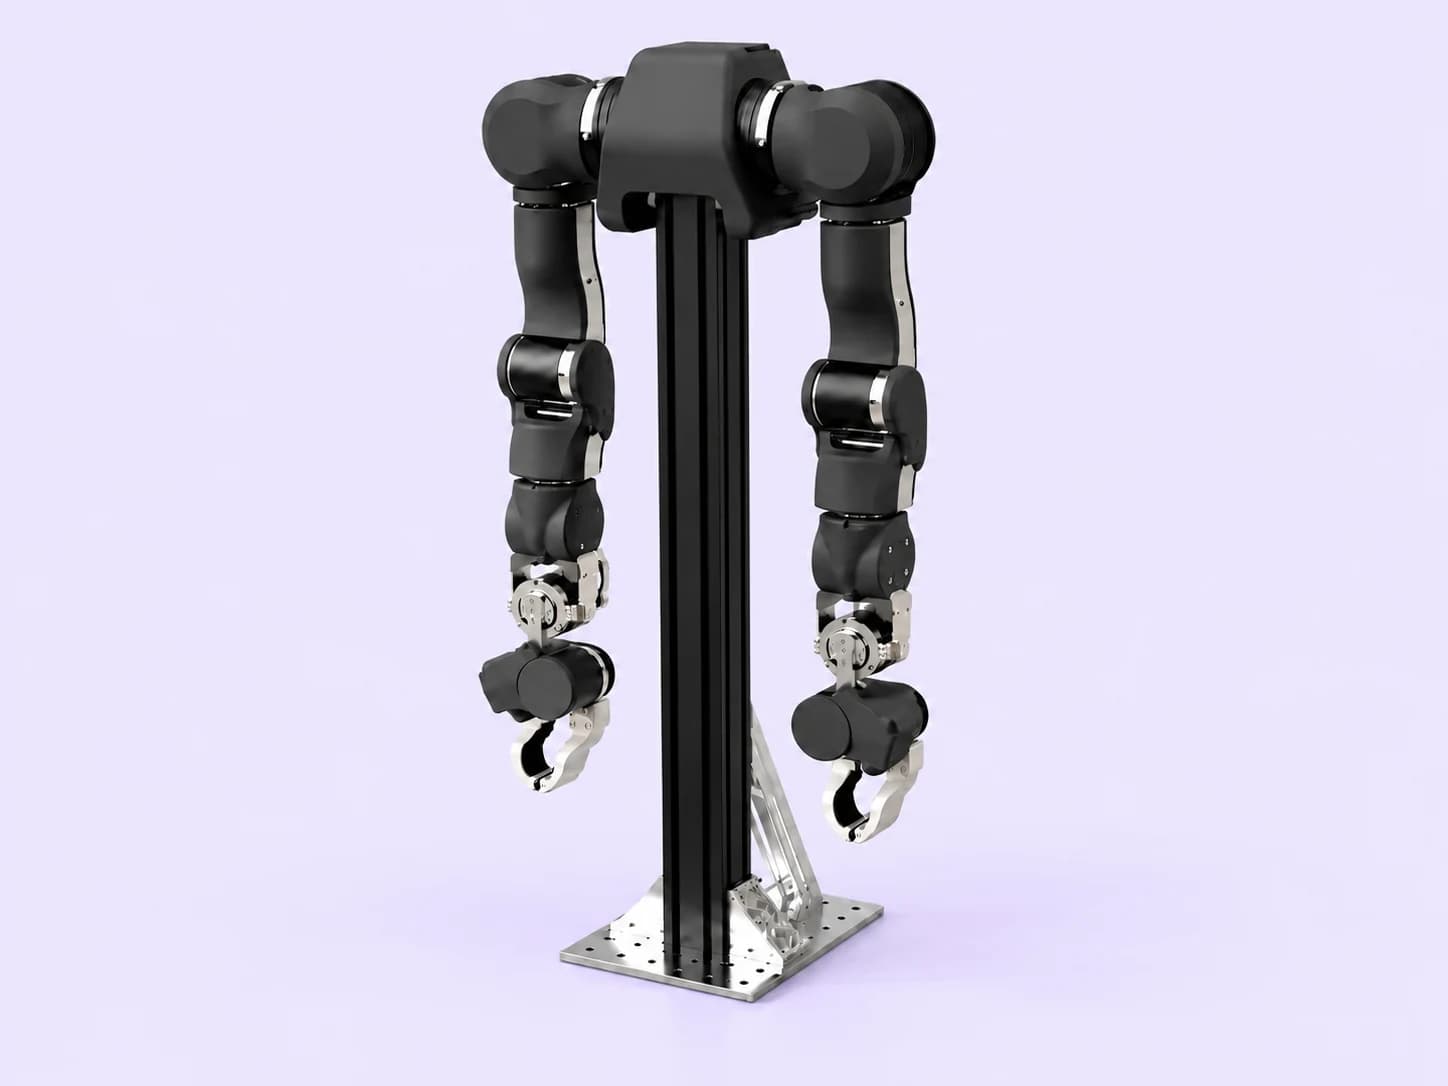
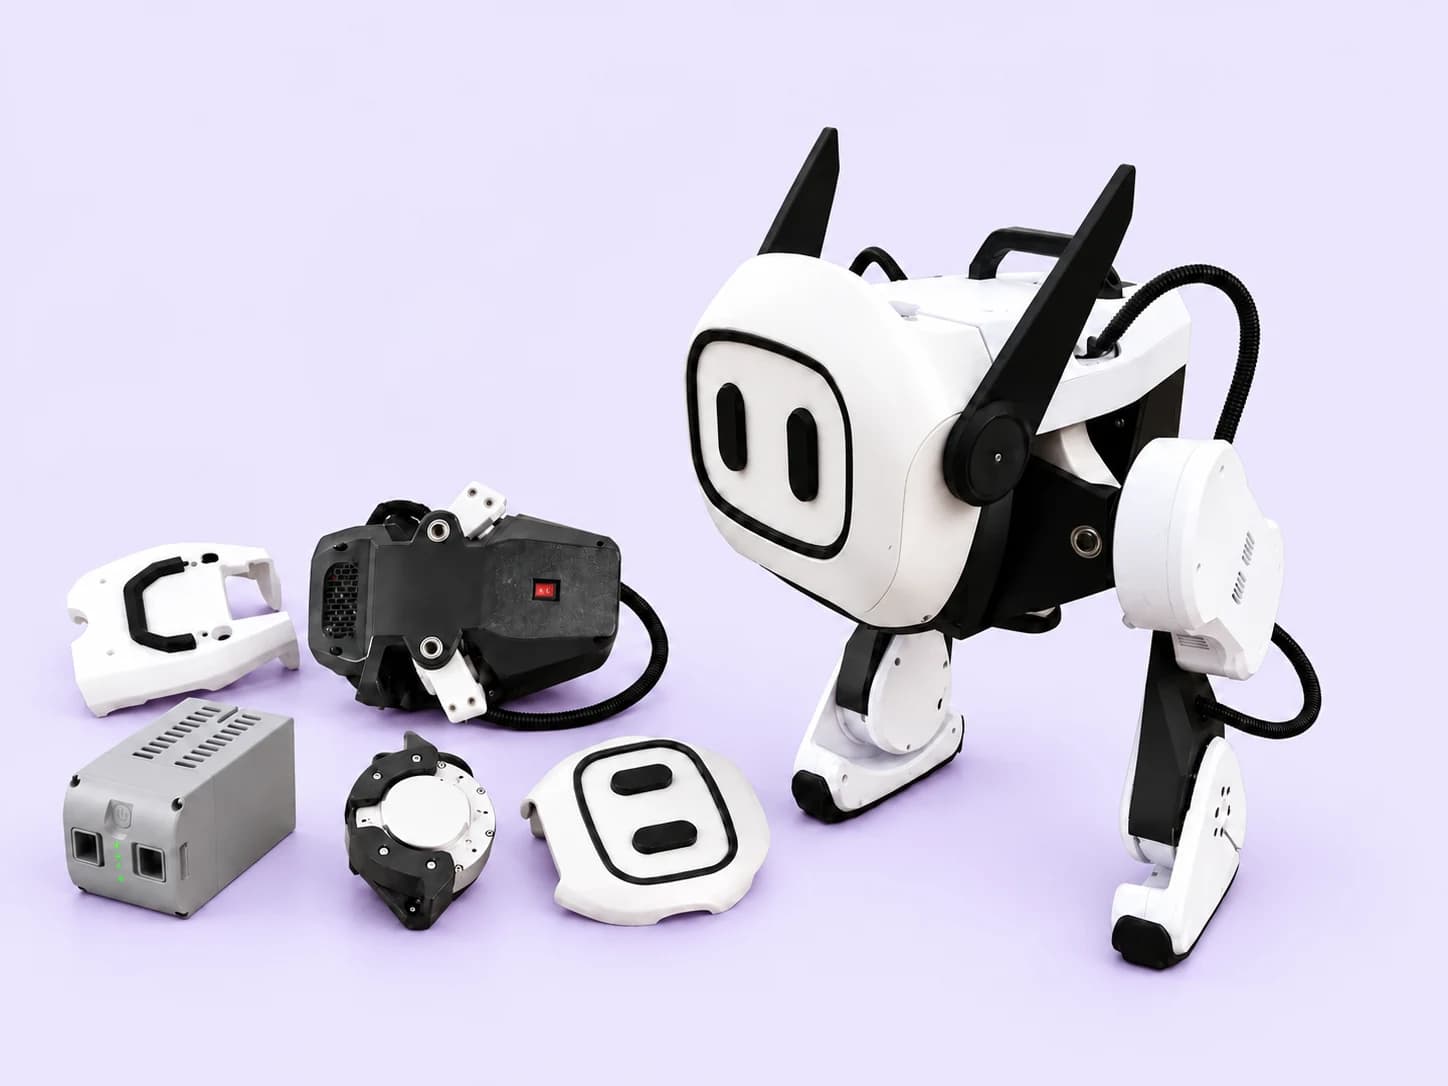
Explore open-source bipedal and manipulation projects for locomotion, learning and physical interaction. Build resources and simulation tools are identified separately for each upstream project.