Skip to content
DuolixDuolix
HomeAll RobotsKits & partsEvents

My

Saved itemsOrders

Explore

Developer docsCommunity
AboutSupportPrivacy

© 2026 Duolix

Duolix
HomeProjectsQmini
Qmini

Qmini

Uploaded byDuolix Labs

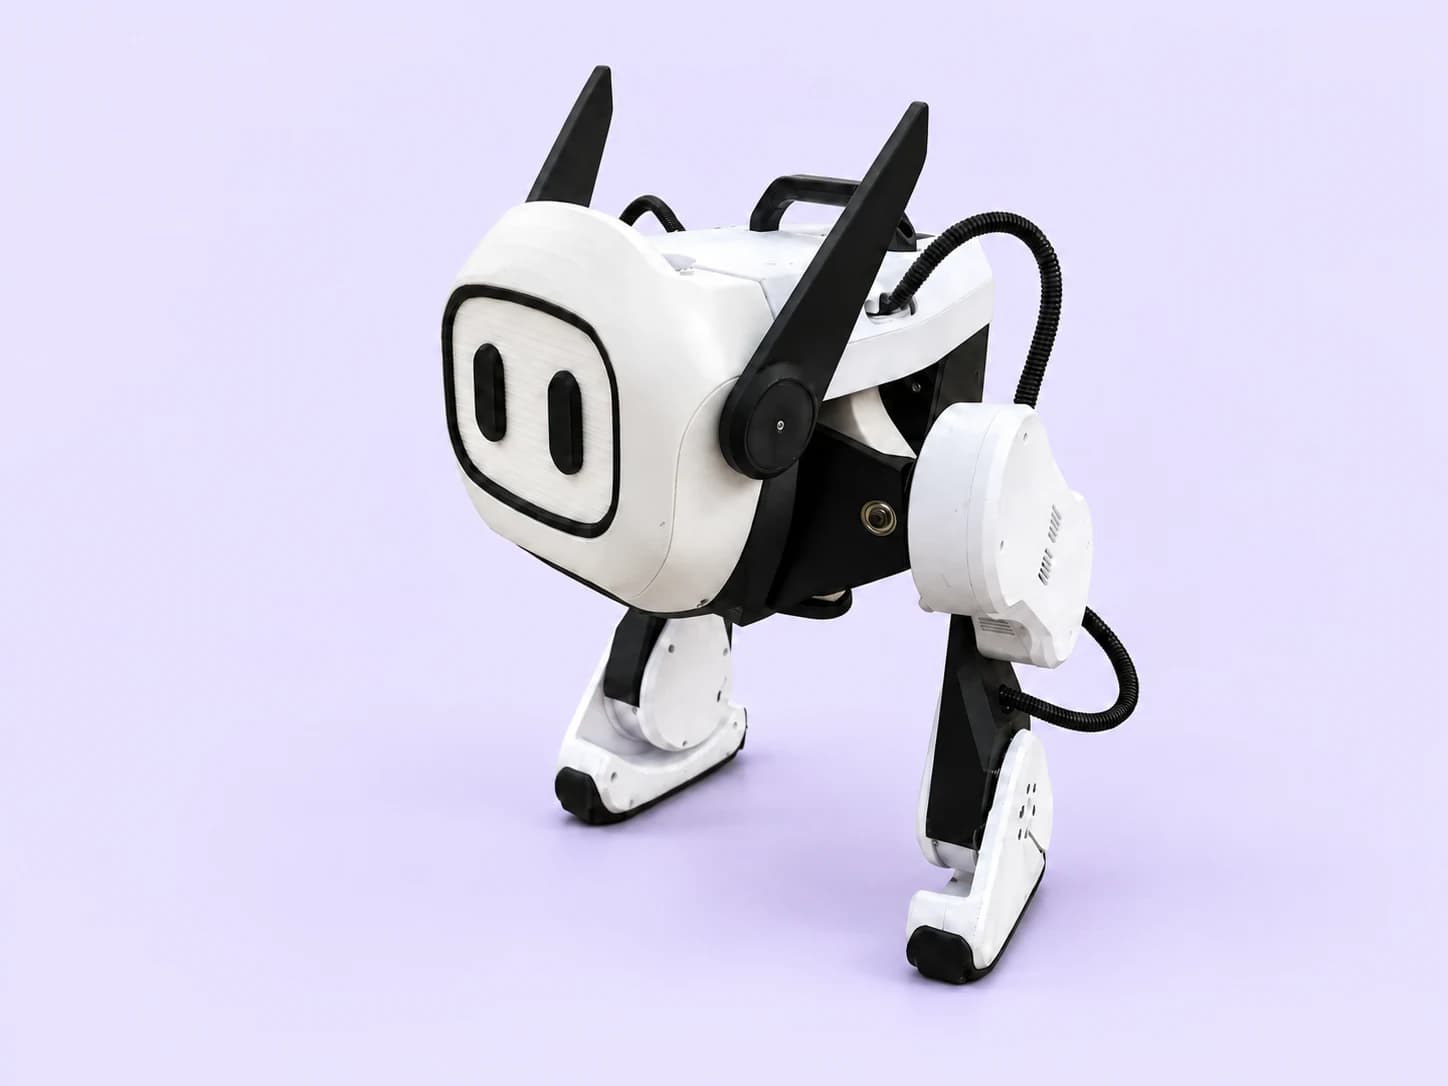
A modular open-source biped for motion control and edge AI development.

  • Modular, 3D-printable structure
  • 11 Unitree M8010 joint motors
  • 12 TOPS on-device AI
  • Simulation-to-robot workflow
View BOMFind your kit
Source project

Qmini is a compact open-source biped designed for builders, educators, and robotics researchers. Its printable modular structure, integrated joint drives, open URDF, and published build resources make it a practical base for studying locomotion, embodied interaction, and edge AI. This Duolix entry uses the Qmini materials prepared for the 2026 Qualcomm IoT Day display; candidate demos still require validation on the physical robot.

Specifications
Architecture
Modular open-source biped
Actuation
11 × Unitree M8010 integrated joint motors
Peak joint torque
23.7 N·m
Edge compute
Qualcomm QCS6490 · 12 TOPS
Resources
BOM · DIY guide · STEP · URDF
Assembly estimate
3–5 hours after parts are prepared
Difficulty
Advanced
Start here
Build
Develop

Getting started

Understand the Qmini architecture and choose a safe starting point.

Start from the published project

Qmini is an open-source biped with a published BOM, DIY guide, STEP files, URDF, and a community control stack. Review those resources before sourcing or printing anything.

Treat display-card capabilities as project context, not a promise that every demo is ready out of the box.

Choose your path

Begin with the URDF and software resources if your focus is control. Begin with the DIY guide and mechanical files if your focus is assembly.

  • Source: github.com/unitreerobotics/Qmini
  • Control stack: github.com/vsislab/RoboTamer4Qmini
  • Physical work: use a stable stand or safety tether for first motion tests.
Download BOM
IncludeComponentQtyUnit priceTotal
Printed mechanical parts and fasteners

Print from the published files and verify fit before assembly

Out of stock

1$899.00$899.00
Unitree M8010 joint motor

Ten locomotion joints plus one neck expansion joint

Out of stock

11$149.00$1,639.00
QCS6490 edge AI compute board

APLUX reference configuration used for the display project

Out of stock

1$399.00$399.00
Depth camera

For near-field perception and interaction experiments

Out of stock

1$99.00$99.00
Battery and power system

Match voltage, discharge rate, connectors, and protection to the final build

Out of stock

1$129.00$129.00
0 components selected · $0.00

These parts are currently unavailable to add. You can still download the BOM and use the source files to plan your build.

RoboTamer4Qmini

Explore the community control software for Qmini.

software · vsislab · Community
Qmini URDF & CAD

Robot models and mechanical files from the source project.

model · Unitree · Upstream